Research
I build models that understand, predict, and act in the dynamic 3D world.
Physical World
Understanding
Recovering geometry, motion, and spatial relationships from sensory observations to understand changing physical environments.
Physical World
Prediction
Developing world models that retain scene knowledge and use geometric constraints to generate coherent, physically plausible futures.
Physical World
Interaction
Enabling robots to learn from multimodal feedback and execution experience, correct errors, and adapt their behavior through interaction.
Recent Work
See my Google Scholar for the full list.
Stream3D: Sequential Multi-View 3D Generation via Evidential Memory
ECCV OpenSUN3D 2026 Best Paper Finalist
GEM-4D: Geometry-Enhanced Video World Models for Robot Manipulation
ECCV 2026 · CVPR WMAS 2026 Best Paper Finalist
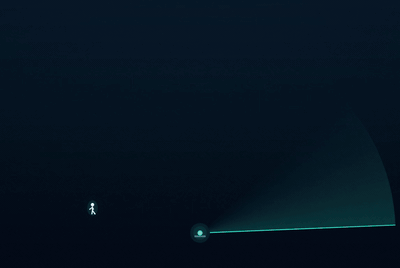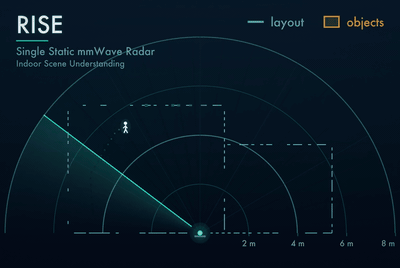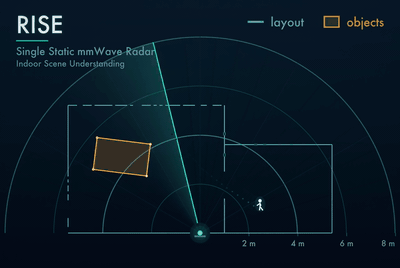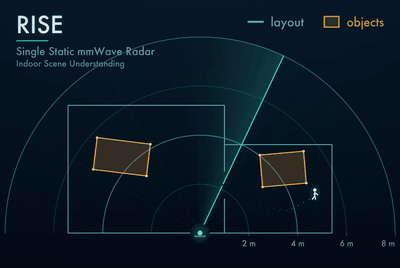
RISE: Single Static Radar-based Indoor Scene Understanding
CVPR 2026 · CVPR GCV 2026 Best Paper Finalist
More Publications
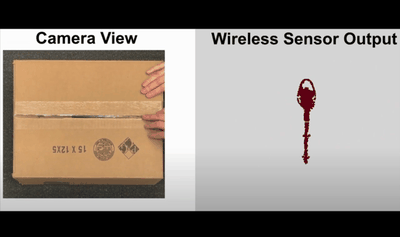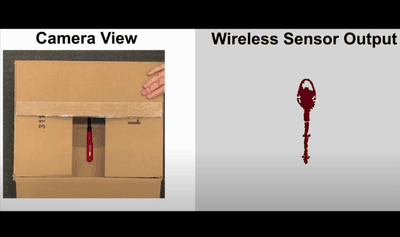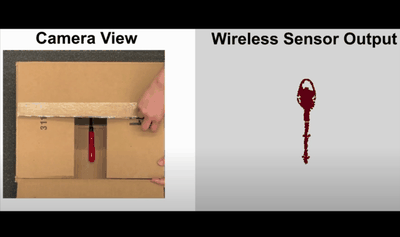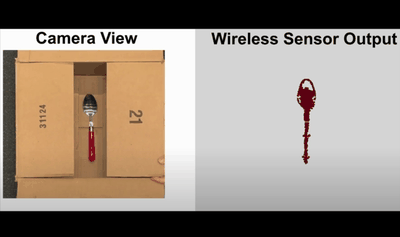
Non-Line-of-Sight 3D Object Reconstruction via mmWave Surface Normal Estimation
ACM MobiSys 2025 · Best Paper Nominee
SCANet: Correcting LEGO Assembly Errors with Self-Correct Assembly Network
IROS 2024 · Finalist, Best Application Paper Award
Awards
Activities
Students
Wonderful students I work with / have worked with.